

Walking time
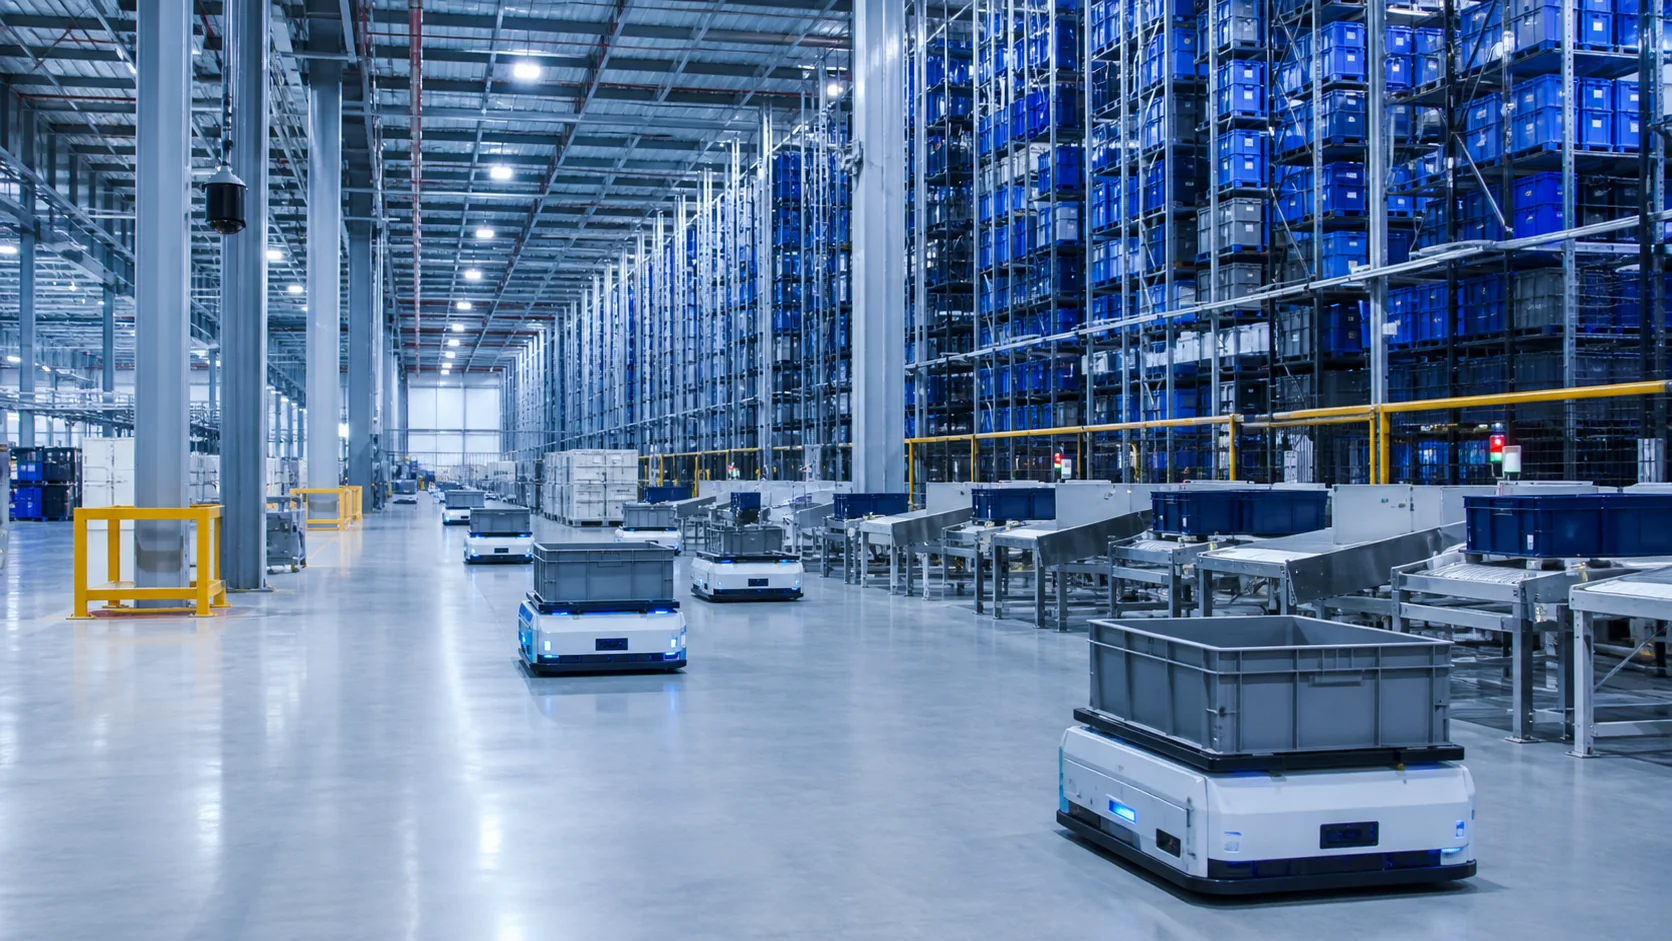
Most of the picking time should not be spent walking between racks.
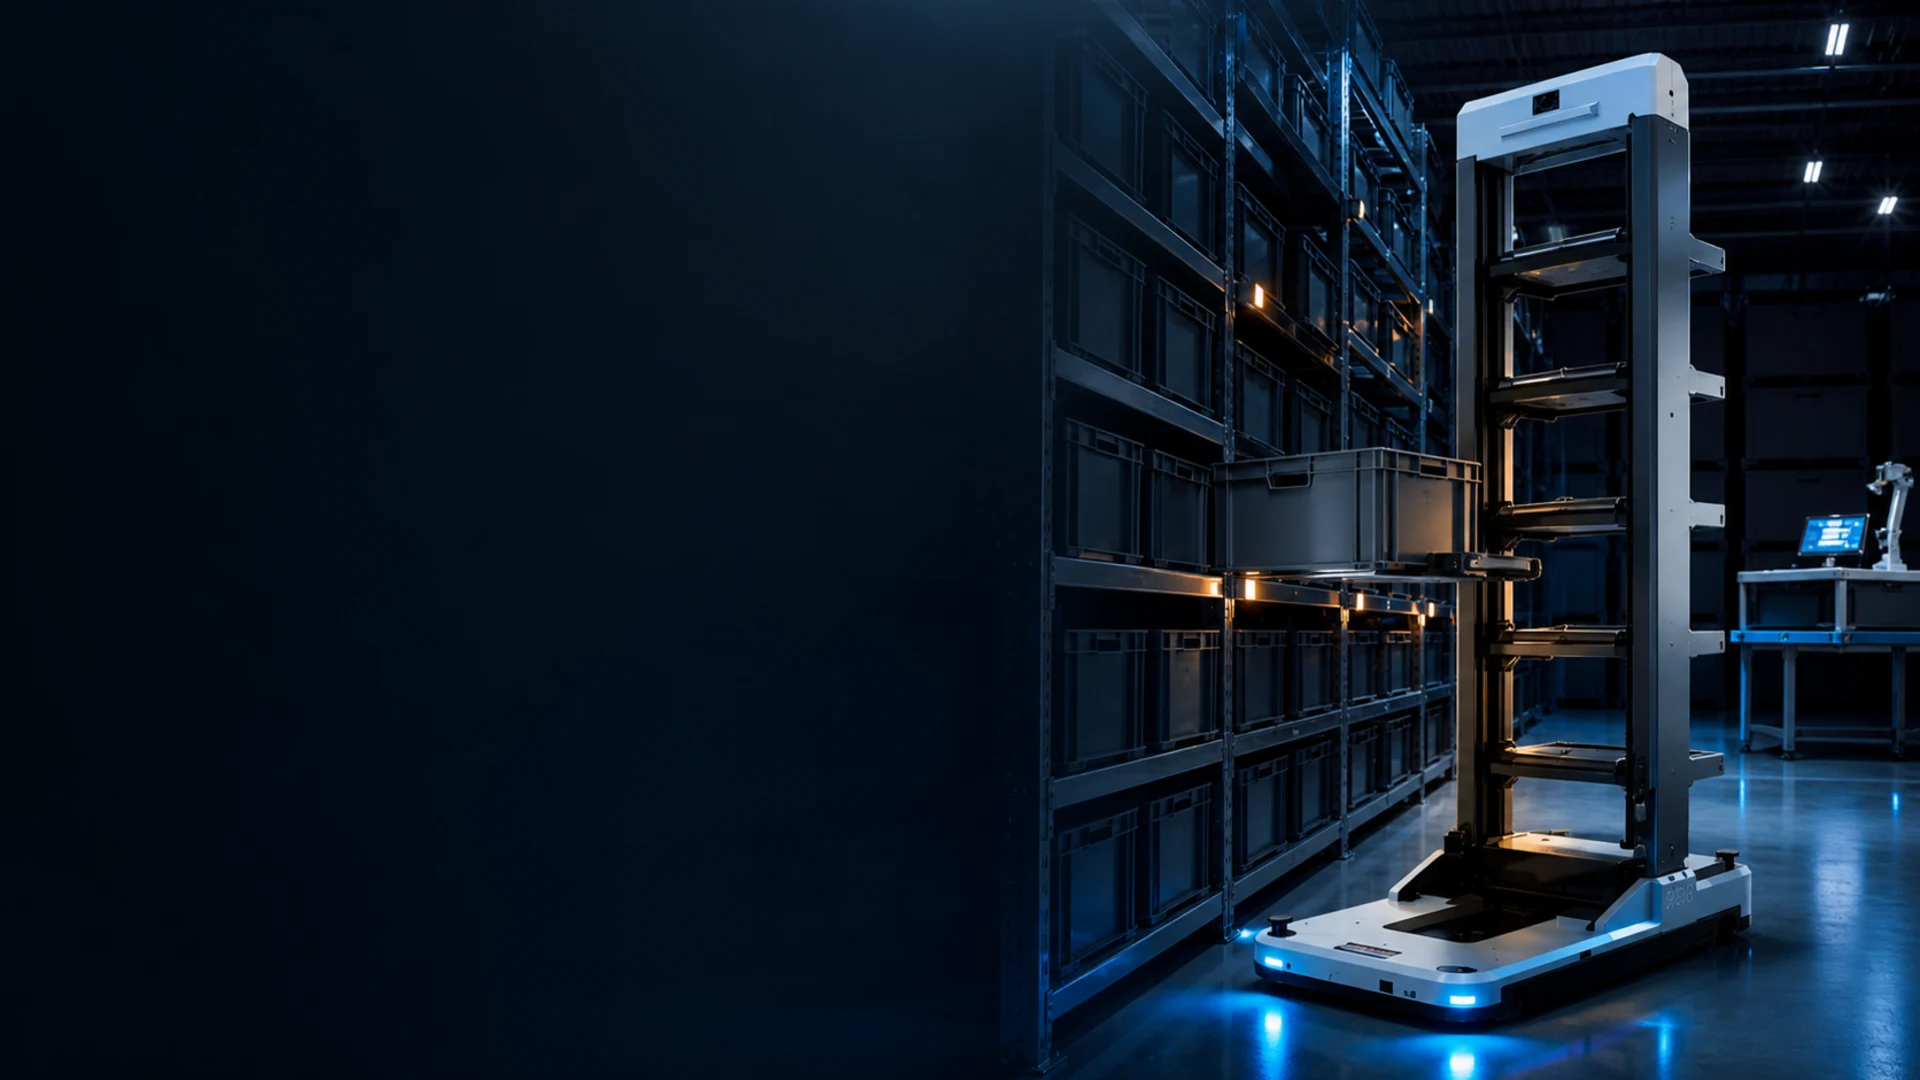
With its vertical storage module and automated loading mechanism, CTU handles multiple totes within a single mission to increase picking density and throughput.
Explore
Most of the picking time should not be spent walking between racks.
Vertical space should not stay unused for the sake of aisle width.
The system must verify that the right tote reaches the right station.
CTU picks the target tote from its rack location, buffers it in the onboard vertical storage module and carries several totes to the picking station in a single run.
CTU models share the same mission logic and differ by bin quantity, picking height, aisle width and tote size.
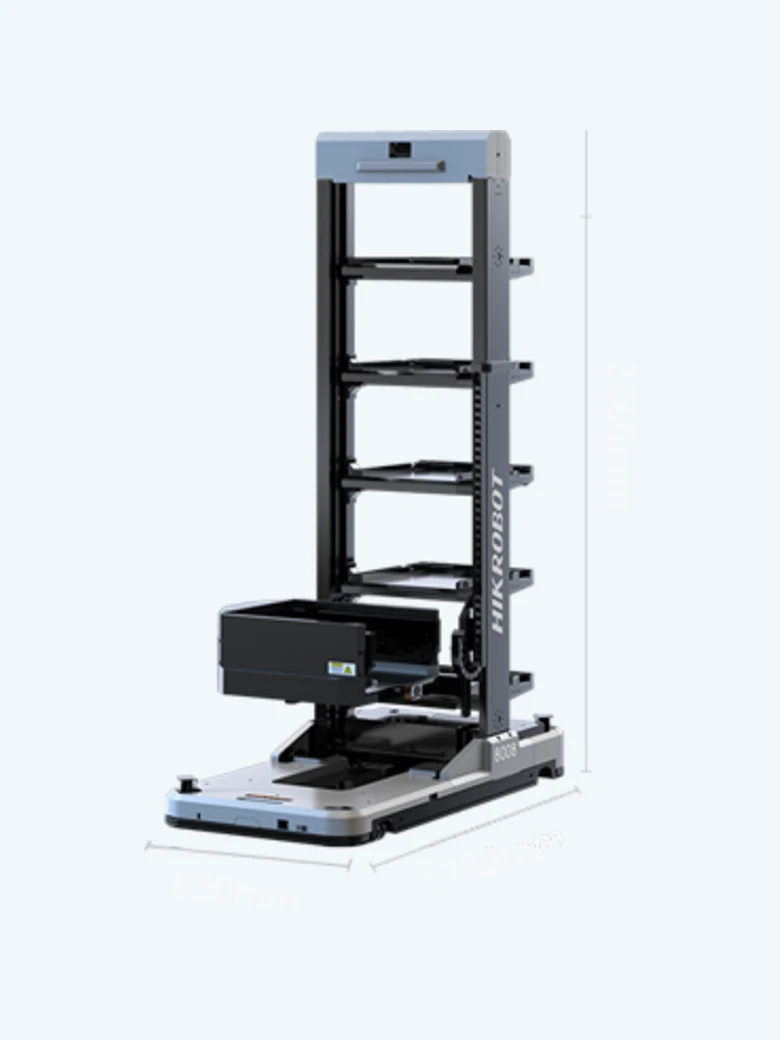
Its compact body suits low racking and dense picking areas.
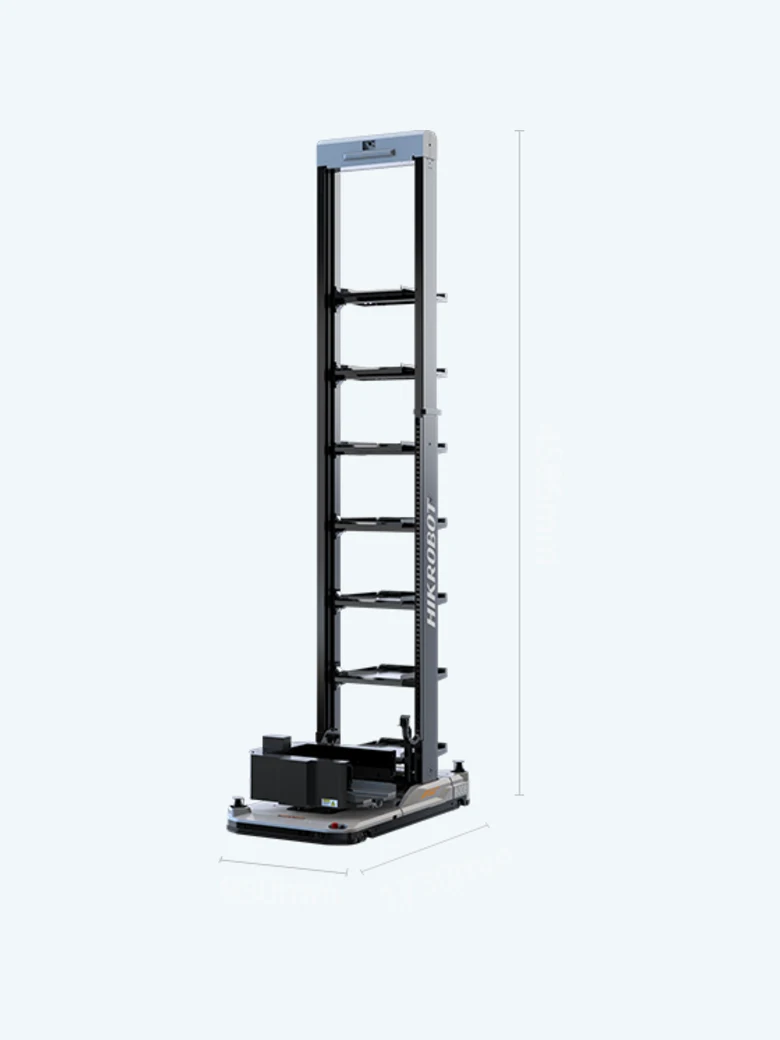
The extended mast reaches rack levels up to four metres.
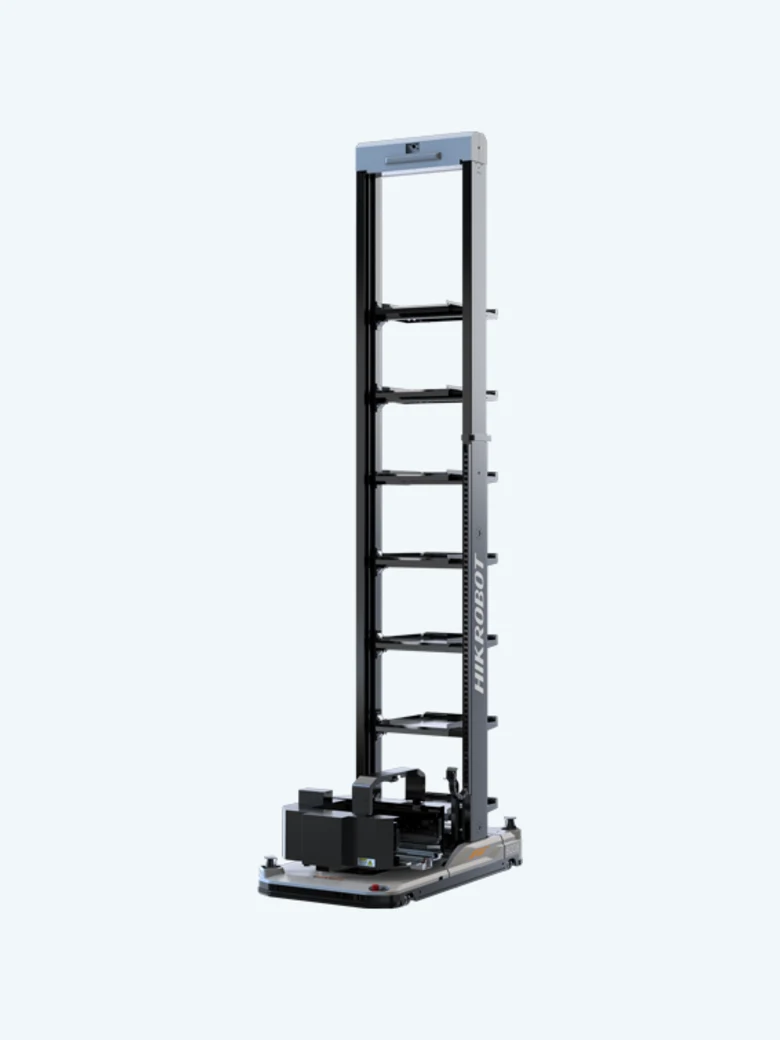
Handles varying tote sizes in double-deep storage layouts.
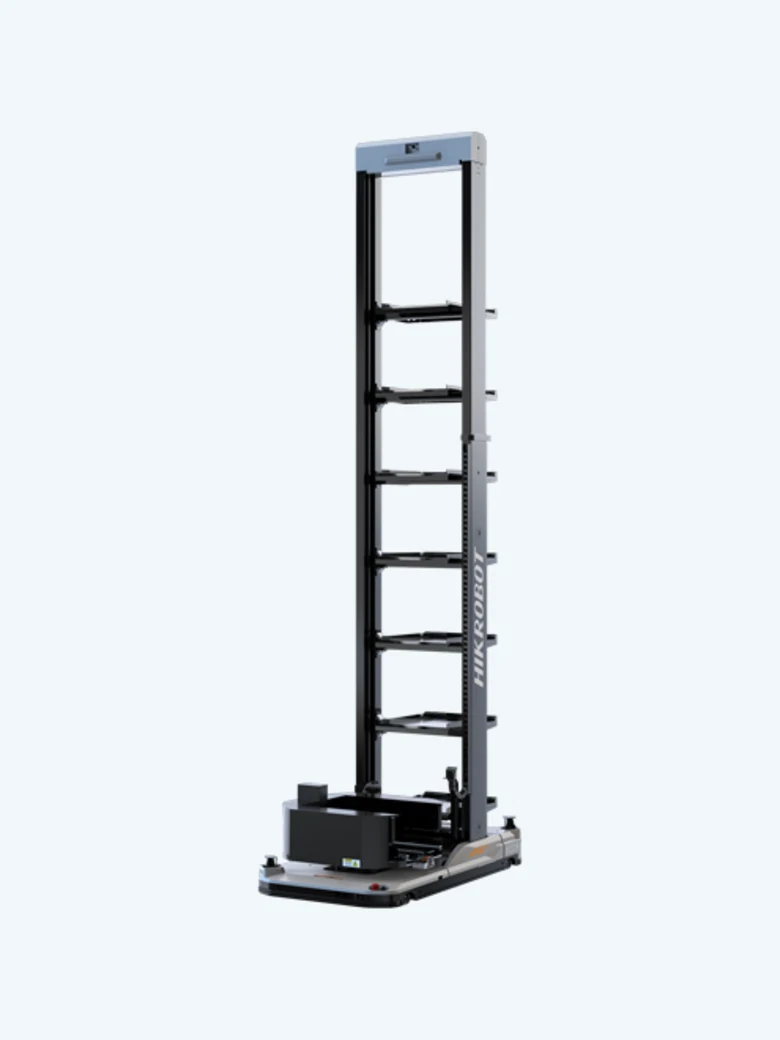
Pickup layout adapted to wide tote profiles.
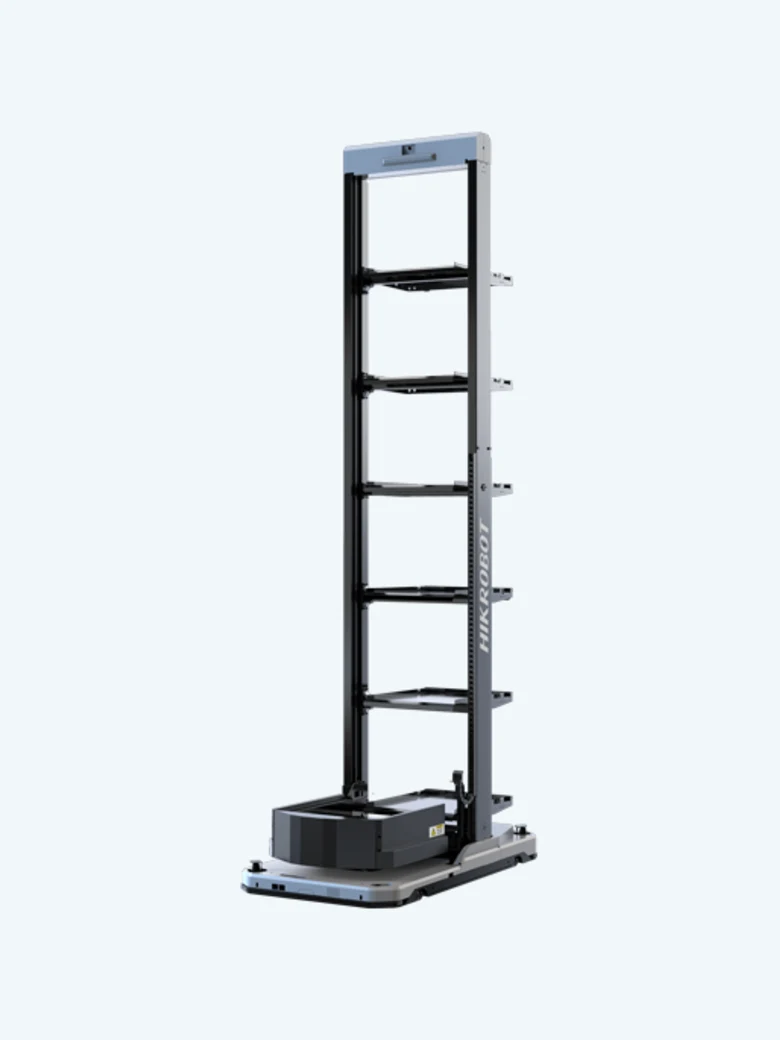
Extended chassis and load area for large, heavy totes.
Values are taken from Hikrobot product documentation; cycle and capacity calculations are made separately for each project.
| Specification | F0-50DC | F0-50DCH | F0-50DCH(D) | F0-50DCH(A) | F0-50DCW |
|---|---|---|---|---|---|
| Rated load (kg) | 250 | 250 | 250 | 250 | 250 |
| Bin quantity | 5 | 7 | 7 | 7 | 6 |
| Adaptable tote size (mm) | (200-620)*(200-450)*(120-360) | 600*400*(120~420) | (300~600)*(300~400)*(120~420) | (450~620)*(200~450)*(120~350) | (630~800)*(550~600)*(120~420) |
| Picking height (mm) | 280~2087 | 270~4000 | 300~4000 | 300~4000 | 300~4170 |
| Aisle width (mm) | 1000 | 1100 | 1100 | 1100 | 1270 |
| Max. lifting speed (mm/s) | 500 | 500 | 500 | 500 | 500 |
| Dimensions L*W*H (mm) | 1730*850*2600 | 1730*950*4565 | 1730*950*4565 | 1730*950*4565 | 2015*1120*4740 |
| Weight with battery (kg) | 605 | 720 | 760 | 737 | 780 |
| Rated speed (m/s) | 1.5 | 1.8 | 1.8 | 1.8 | 1.8 |
| Positioning accuracy (mm, °) | ±10, ±1 | ±10, ±1 | ±10, ±1 | ±10, ±1 | ±10, ±1 |
| Charging time (h) | ≤2 | ≤2 | ≤2 | ≤2 | ≤2 |
| Operating time (h) | 6~8 | 6~8 | 6~8 | 6~8 | 6~8 |
Carrying five to seven totes per mission reduces the number of runs per station.
Operators no longer search the racks; the target tote arrives at the station in the right sequence.
Narrow aisles and tall racking increase stock density per square metre.
Totes collected from different zones are combined in one run and handed to packing.
Customer and facility information has been anonymized to meet confidentiality obligations.
Share load profiles, throughput targets and space constraints so the right architecture can be assessed.
Request a storage and flow analysis Your request is routed directly to the relevant engineering team.
Engineering confidence with Oskon.
Leave your details and our expert engineers will contact you for a preliminary consultation tailored to your needs.